
AI Assistant
Cart
Quote
Rotating Cross Cutter Firmware CT803
SKU: CT803
Out of stock
Availability: Out of Stock
Marketplace sellers
Submit a quote request to receive offers from sellers of this product.
Short Description
Pricing available on request
Description:
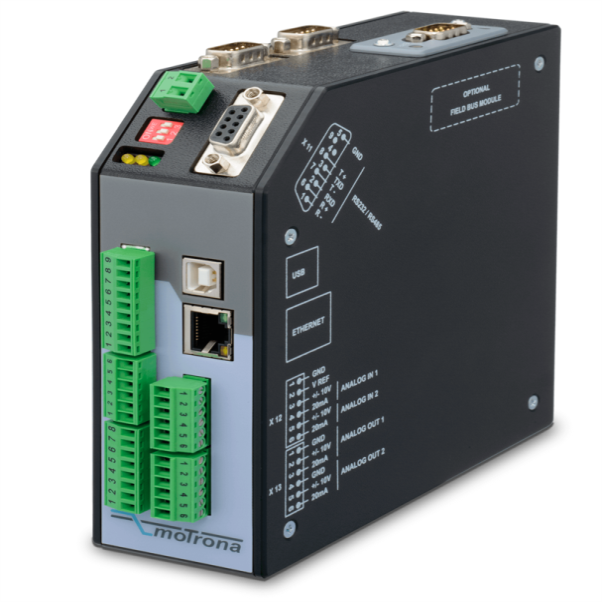
Following in the footsteps of the successful MC700, the MC800 multi-axis motion controller is impressive due to its even more flexible bus architecture and even higher bandwidth.
Different encoder and sensor systems can be connected thanks to universal encoder inputs.
The integrated tandem drive controller, a unique feature of this drive control, allows power distribution on two separate drives to meet the acceleration need of a following axis.
Together with the MC800 hardware, the CT803 firmware excels in precision cutting, high dynamics, and quick position control cycles for devices like rotary crosscutters and other rotary applications.
Buy currently uses Select Automation shop pricing and checkout.
Specifications:
2 pulse inputs with format A, /A, B, /B, Z, /Z [HTL, RS422] with an input frequency up to 2 MHz.
2 control inputs with format SIN+, SIN-, COS+, COS- [1 Vss] with an input frequency up to 400 kHz.
2 SSI inputs with format DATA+, DATA-, CLOCK+, CLOCK- up to 25 Bit, with SSI switching frequency of 100 Hz ... 1 MHz.
2 scalable 14-bit analog inputs for ±10 V or 0/4 ... 20 mA.
4 control inputs for PNP / NPN signals [10 ... 30 VDC].
4 fast interrupt inputs for PNP / NPN signals [10 ... 30 VDC].
1 pulse output with format A, /A, B, /B, Z, /Z [RS422].
4 control outputs with push-pull characteristic, short-circuit-proof [5 ... 30 VDC].
2 scalable 14-bit analog outputs for ±10 V or 0/4 ... 20 mA.
Loop time approx. 250 µs.
Power supply 18 ... 35 VDC.
Snap-on housing for top hat rail (according to EN 60715).
OnBoard interfaces: Ethernet / IP, RS232 / RS485, USB 2.0, CANopen, Modbus RTU.
Optional Ethernet interfaces: EtherCAT, Ethernet / IP, Modbus TCP, Powerlink, PROFINET, SERCOS III.
Optional Fieldbus interfaces (slave): CC-Link, DeviceNet, PROFIBUS.
Operates with all 4-Q-drive systems, equipped with a standardized drive communication bus (e. g. SERCOS-II). Alternatively, ±10 V setpoint can be used.
The controllers can be setup by an external operator terminal as well as HMIs via standardized factory communication bus e. g. PROFINET.