
AI Assistant
Cart
Quote
EL7037 EtherCAT Terminal, 1-channel motion interface, stepper motor, 24 V DC, 1.5 A, with incremental encoder
SKU: EL7037
Out of stock
Availability: Out of Stock
Marketplace sellers
Submit a quote request to receive offers from sellers of this product.
Short Description
Connection method: direct motor connection + feedback
Number of inputs: 2 x end position, 1 x encoder
Load type: 2-phase stepper motor (uni-/bipolar)
Number of channels: 1
Number of outputs: 1 x stepper motor, 1 x motor brake
Supply voltage electronics: 24 V DC (via power contacts)
Supply voltage power: 24 V DC (internally via power contacts)
Output current: max. 1.5 A
Performance increase:yes, through ZB8610 fan cartridge
Output current with ZB8610: max. 3.0 A
Step frequency: configurable up to 16,000 full steps/s
Step pattern: 64-fold micro stepping
Current controller frequency: approx. 30 kHz
Resolution: approx. 5000 positions in typ. applications (per revolution)
Encoder input signal: 5…24 V DC, typ. 5 mA, single-ended
Input frequency: max. 400,000 increments/s (with 4-fold evaluation)
Current consumption power contacts: typ. 50 mA + motor current
Current consumption E-bus: typ. 100 mA
Distributed clocks: yes
Special features: travel distance control, encoder input, vector control
Electrical isolation: 500 V (E-bus/field potential)
Relative humidity: 95 %, no condensation
Weight: approx. 50 g
Operating/storage temperature: 0…+55 °C/-25…+85 °C
EMC immunity/emission: conforms to EN 61000-6-2/EN 61000-6-4
Vibration/shock resistance conforms to EN 60068-2-6/EN 60068-2-27
Protect. rating/installation pos.: IP20/see documentation
Pluggable wiring –
Approvals/markings: CE, UL
Buy currently uses Select Automation shop pricing and checkout.
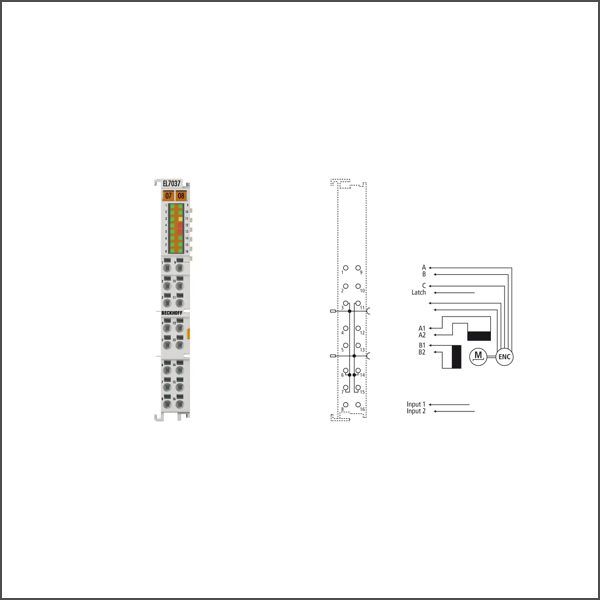
The EL7037 EtherCAT Terminal is intended for the direct connection of stepper motors in the low power range up to 1.5 A.